Mengjun Wang | 王梦君

mwang5 at ufl dot edu

I am a Ph.D. candidate in Civil Engineering at the University of Florida, advised by Prof. Shuai Li.

My research focuses on Physical AI for construction and infrastructure, connecting task-relevant sensing and physical-state estimation, digital-to-physical task grounding and spatial guidance, and adaptive human and robotic execution.

I received M.S. degrees in Civil Engineering and Computer Science from the University of Tennessee and a B.S. in Traffic Engineering from Changsha University of Science and Technology.

Mengjun Wang

News

SHOW MORE...HIDE...

Selected Research

My research develops task-grounded Physical AI for construction and infrastructure, with a focus on connecting physical-world understanding, project-specific intent, and human or robotic action.

Mobile robot projecting a BIM-derived installation pattern onto a construction wall

Bringing BIM-Grounded Guidance to the Jobsite: A Mobile SAR Co-Pilot for MEP Layout

Mengjun Wang, Dingyuan Huang, Shuai Li, Jiannan Cai, Yuqing Hu

Explores agentic robots that extend construction supervision through on-demand field guidance, quality assessment, and reporting under human control.

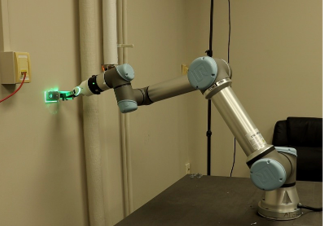
Robot aligning a bracket against a projected workface reference

Robotic Alignment of Construction Components via a BIM-to-Workface Projection Interface

Mengjun Wang, Jing Du, Jiannan Cai, Shuai Li

Develops a BIM-grounded projection interface that enables robots to align construction components using visual feedback and learned control.

BIM-driven laser projection workflow for in-situ guidance

BIM-driven laser spatial augmented reality for in-situ layout and assembly

Mengjun Wang, Jianjun Xu, H. Andrew Lassiter, Shuai Li

Automation in Construction, 2025

Transforms BIM design information into full-scale laser projections to provide spatial guidance for on-site construction layout and assembly.

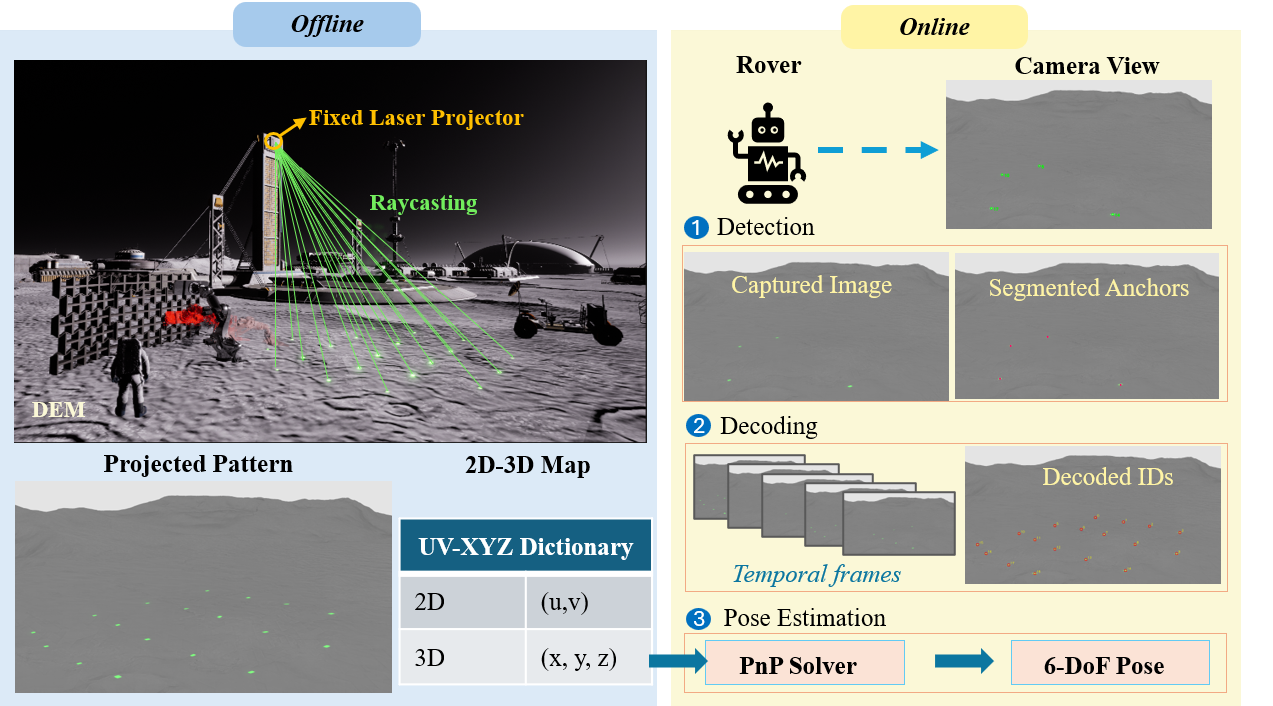
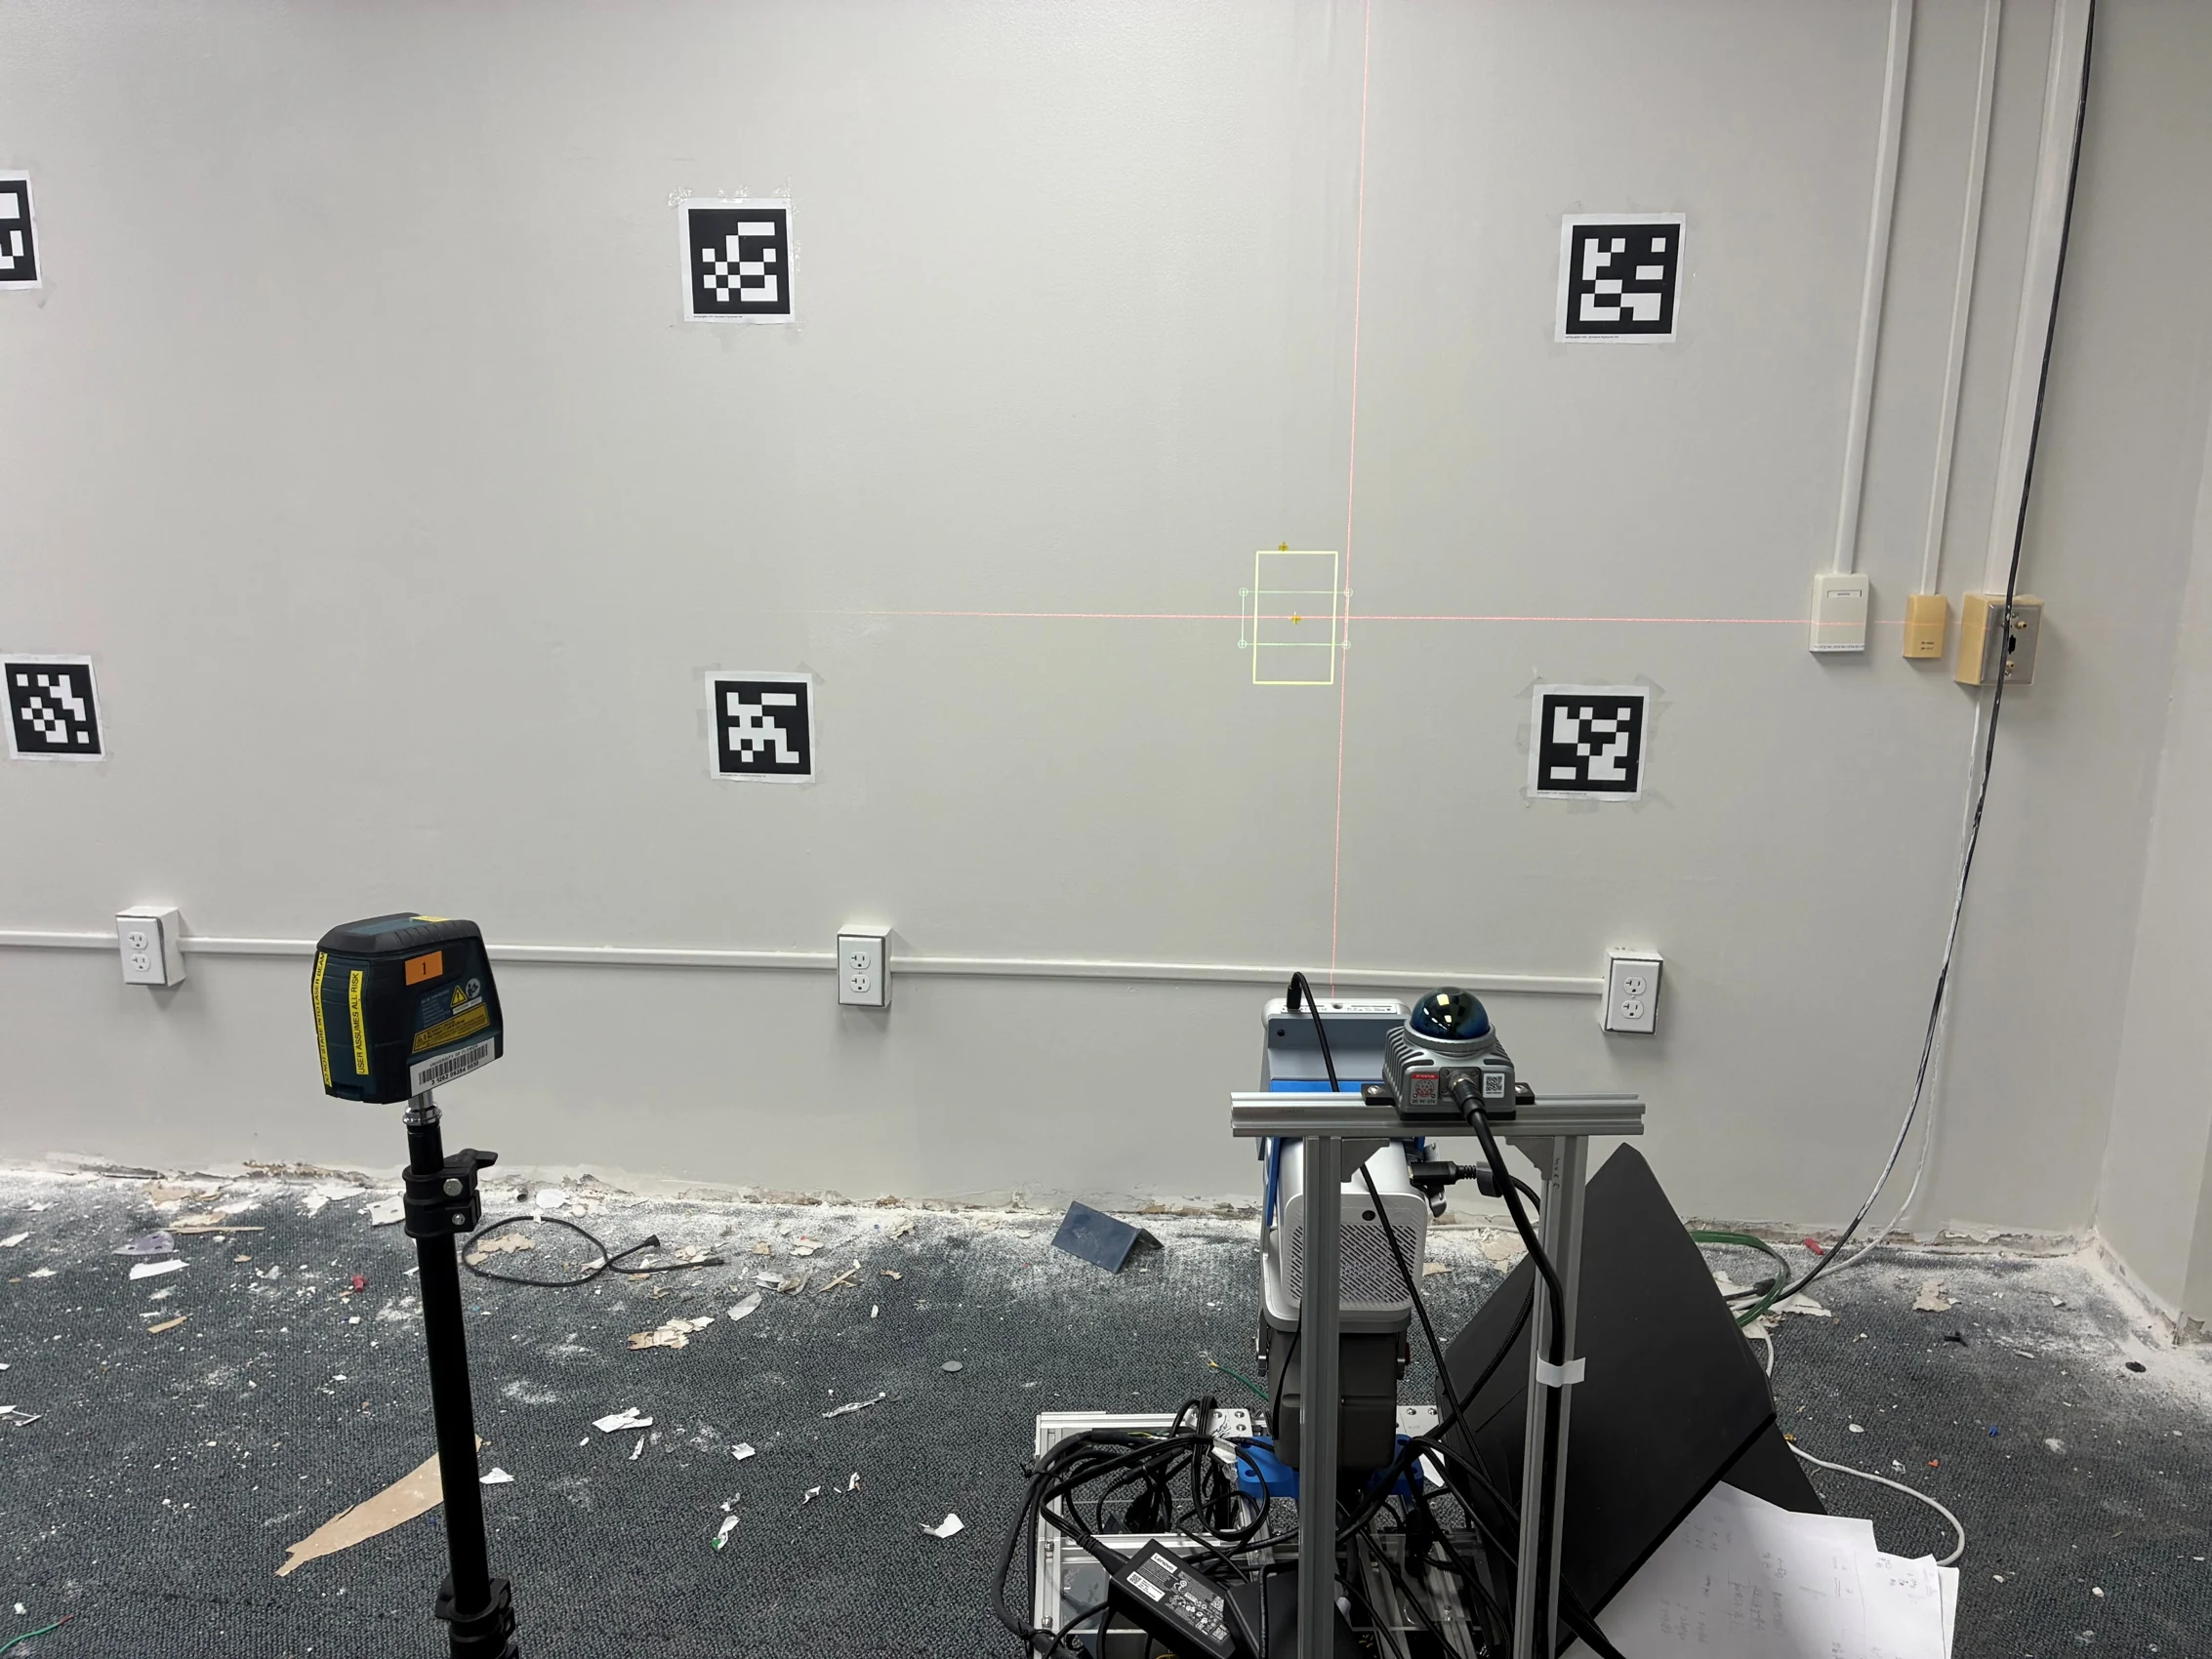
Robotic localization with active projected fiducials for lunar construction

Robotic localization via active projected fiducials for space construction

Mengjun Wang, Shuai Li, Yunlan Zhang

Journal of Computing in Civil Engineering — In Production

Investigates actively projected visual references for robotic localization in feature-sparse lunar construction environments.

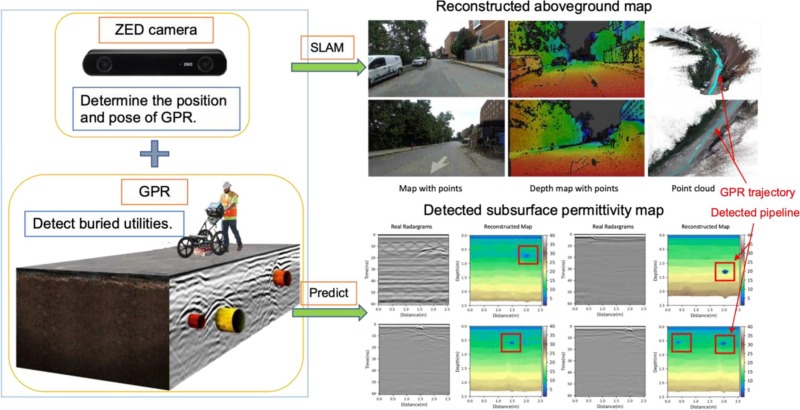
Ground-penetrating radar detection and underground infrastructure mapping

Underground infrastructure detection and localization using deep learning enabled radargram inversion and vision-based mapping

Mengjun Wang, Da Hu, Junjie Chen, Shuai Li

Automation in Construction, 2023

Integrates deep-learning-based GPR inversion with vision-based mapping to reconstruct and spatially localize buried utilities.

Collaborative Research

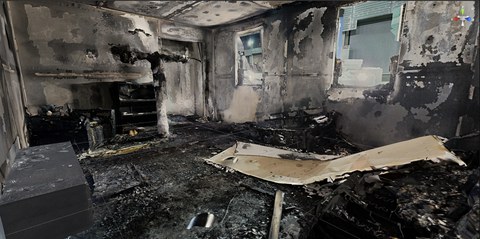
Fire-damaged room in the interactive investigation environment

Interactive Fire Investigation Training through Simulation

Develops an interactive training environment for fire scene reconstruction, evidence interpretation, and simulation-based hypothesis testing.

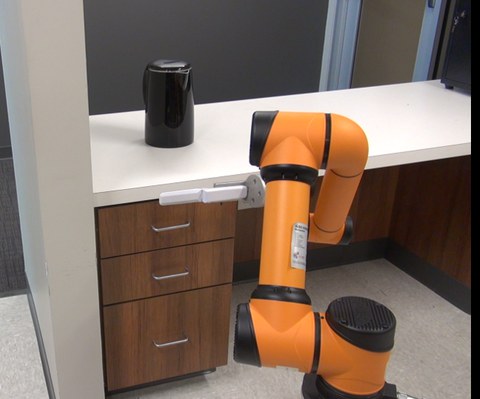
Physical robot arm in a cabinet-handle disinfection experiment

Autonomous Robotic Disinfection

Research on robotic perception, semantic environment understanding, and autonomous disinfection in healthcare facilities.

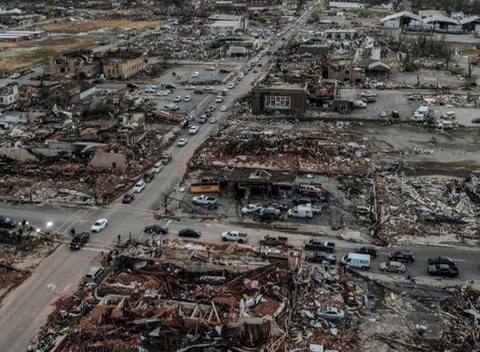
Aerial view of tornado-damaged buildings and debris across a community, NWS/NOAA

Disaster Reconnaissance and Damage Assessment

Research on post-disaster damage assessment and reconnaissance planning to support situational understanding and response.

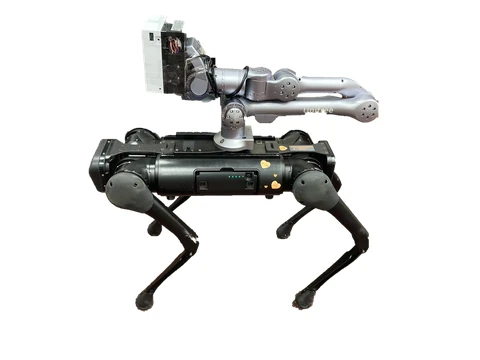
Quadruped robot platform with a mounted manipulator and sensing equipment

Ground-Penetrating Rescue Robots

Explores robotic ground-penetrating sensing, hidden-space understanding, and spatial guidance for disaster search and rescue.

Teaching & Mentoring

Misc.

Outside research, I enjoy swimming, badminton, table tennis. I am learning Japanese and cooking.